Event-Triggered Cooperative Control of Multi-Agent Systems(自动化技术、计算机技术)
| 运费: | ¥ 10.00-25.00 |
| 库存: | 30 件 |
商品详情
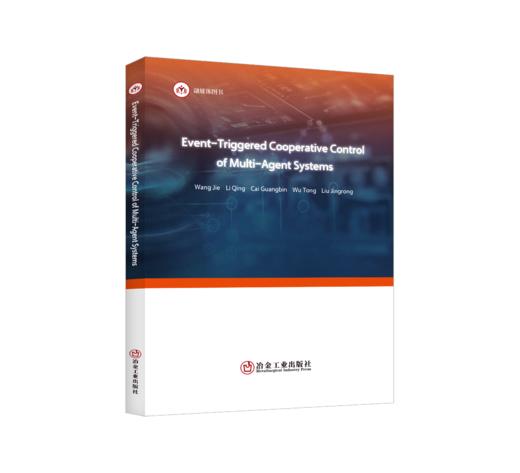
《Event-Triggered Cooperative Control of Multi-Agent Systems》
作者:王婕 李擎 蔡光斌 吴彤 刘京融
定价:138.00元
出版时间:2026-04
ISBN:978-7-5240-0599-5
内容简介
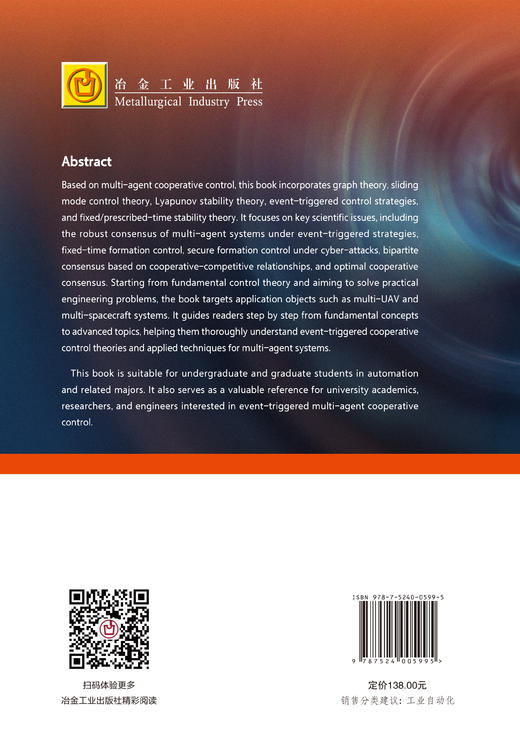
多智能体系统由多个具备通信能力的智能体组成,通过智能体与其邻居智能体间的交流,使所有智能体趋于一致,协同实现单一智能体所无法实现的复杂任务。然而,多智能体系统在实际应用中仍存在许多困难与挑战,如多智能体系统在执行协同任务时需要考虑通信资源受限、任务完成时间限制、智能体状态通信量化、智能体间通信网络被攻击、智能体间存在碰撞隐患以及智能体间存在合作-竞争关系等问题。针对上述种种问题,本书以多智能体协同控制为基础,重点研究事件触发策略下多智能体系统的鲁棒一致性、固定时间编队控制、量化编队控制、网络攻击下安全编队控制、避碰条件下编队控制以及基于合作-竞争关系的二分一致性等问题。全书由控制理论出发,以解决实际工程为目标,面向多飞行器、多机器人等对象,引入图论、滑模控制理论、Lyapunov稳定性理论、事件触发控制策略、固定时间稳定性理论及人工势场法等解决关键科学问题,并通过数学推导和仿真分析相结合的方式验证算法的有效性,由浅入深,帮助读者逐步理解和掌握多智能体系统的协同控制理论,事件触发机制设计、对于理论研究与工程实践具有一定的指导意义。
目录
The authors
November,2025
Contents
Chapter 1 Introduction
1.1 Overview of multi-agent systems
1.2 State of the art in cooperative control of multi-agent systems
1.2.1 Robust cooperative control of multi-agent systems
1.2.2 Event-triggered cooperative control of multi-agent systems
1.2.3 Fixed-time and prescribed-time cooperative control of multi-agent
systems
1.2.4 Cooperative control of multi-agent systems under cyber attacks
1.2.5 Cooperative control of multi-agent systems with
cooperative-competitive interactions
1.3 Structural framework and content organization
1.4 Chapter summary
References
Chapter 2 Robust Consensus of Multi-Agent Systems Under Event-Triggered
Strategies
2.1 Event-triggered consensus control for first-order MASs
2.1.1 Problem formulation
2.1.2 Design of event-triggered sliding mode controller
2.1.3 Simulation result
2.2 Event-triggered consensus control for second-order MASs
2.2.1 Problem formulation
2.2.2 Design of event-triggered sliding mode controller
2.2.3 Simulation result
2.3 Conclusion
Reference
Chapter 3 Robust Secure Synchronization Control for Multiple Neural
NetworksㄩAn Event-Triggered Adaptive Integral Sliding
Mode Method
3.1 Preliminaries and problem formulation
3.1.1 Notations
3.1.2 Problem formulation
3.2 Event-triggered adaptive integral sliding mode control
3.2.1 Attacks on actuators and sensors
3.2.2 Distributed event-triggered adaptive integral sliding-mode
control strategy
3.3 Simulations
3.4 Conclusion
References
Chapter 4 Event-Triggered Secure Consensus for Cyber-Physical Systems
with Dynamic Quantized Measurement
4.1 Problem formulation
4.2 Event-triggered dynamic quantization consensus in multi-agent
systems
4.2.1 Quantizer design and analysis
4.2.2 Design of the control law and the adaptive law
4.2.3 Stability analysis
4.3 Simulations
4.4 Conclusion
References
Chapter 5 Distributed Event-Triggered Control for Bipartite Consensus
Under Complex Cyber Attacks
5.1 Problem formulation
5.2 Event-triggered bipartite consensus of multi-agent systems under
complex cyber attacks
5.2.1 Design and stability analysis of event-triggered sliding mode
controller under false data injection attacks
5.2.2 Event-triggered bipartite consensus under false data injection
attacks and DoS attacks
5.3 Simulations
5.4 Conclusion
References
Chapter 6 Event-Based Dynamic Quantized Control for Bipartite
Consensus
6.1 Problem formulation
6.2 Dynamic quantitative binary consistency control based on
event-triggering
6.2.1 Design of event-triggered sliding mode controller under dynamic
quantization measurement
6.2.2 Multi-agent binary consensus under non-periodic DoS attacks
6.3 Simulations
6.4 Conclusion
References
Chapter 7 Event-Triggered Robust Optimal Consensus Control for
Multi-Agent Systems
7.1 Design of event-triggered fixed-time ISMC
7.1.1 Distributed fixed-time event-based ISMC
7.1.2 Stability analysis under event-triggered control scheme
7.2 Event-based optimal consensus control design
7.2.1 Optimal consensus controller design based on event-triggered
ADP
7.2.2 Event-triggered ADP optimal consensus control algorithm
based on a single neural network
7.3 Simulations
7.4 Conclusion
References
Chapter 8 Fixed-Time Distributed Event-Triggered Formation Control
with State-Dependent Threshold
8.1 Problem formulation
8.1.1 Algebraic graph theory
8.1.2 Basic definitions and related lemmas
8.2 Event-triggered fixed-time formation control for multi-agent
systems
8.2.1 Fixed-time event-triggered formation controller design
8.2.2 Stability analysis
8.3 Simulations
8.4 Conclusion
References
Chapter 9 Output Event-Triggered Tracking Synchronization of
Heterogeneous Systems on Directed Digraph Via
Model-Free Reinforcement Learning
9.1 Problem formulation
9.2 Optimal event-triggered control design based on distributed
observers
9.2.1 Optimal controller design based on distributed observers
9.2.2 Optimal event-triggered controller design
9.2.3 Feasibility analysis
9.3 Model-free adaptive dynamic programming algorithm
9.4 Simulations
9.5 Conclusion
References
- 冶金工业出版社图书旗舰店
- 冶金工业出版社,是国内历史最悠久的专业科技出版社之一。主要承担学术专著、技术著作、技术手册、专业辞书、大中专教材、职工培训教材、科普读物、人文社科、文集、史志、年鉴等图书的出版。
- 扫描二维码,访问我们的微信店铺