商品详情
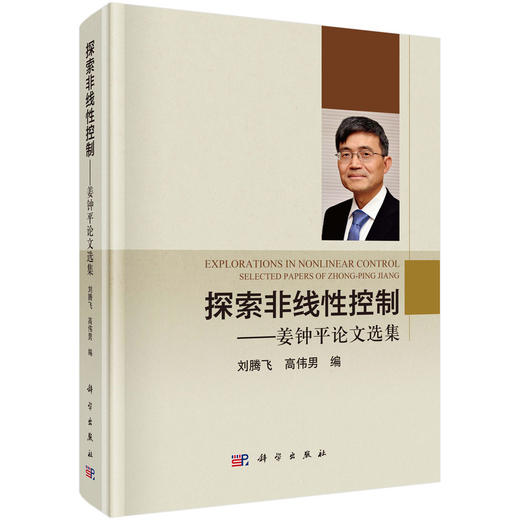
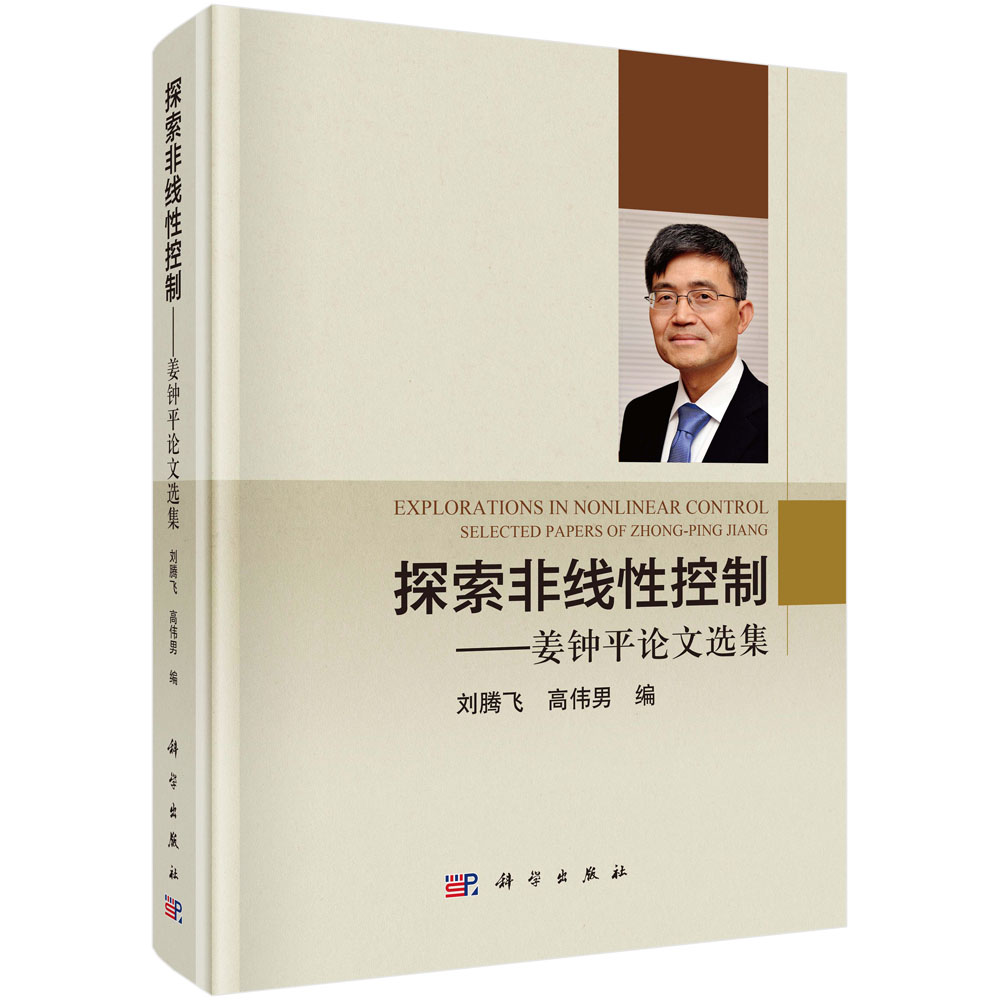
书名:探索非线性控制——姜钟平论文选集
定价:268.0
ISBN:9787030857095
作者:刘腾飞,高伟男,编
版次:1
出版时间:2026-09
内容提要:
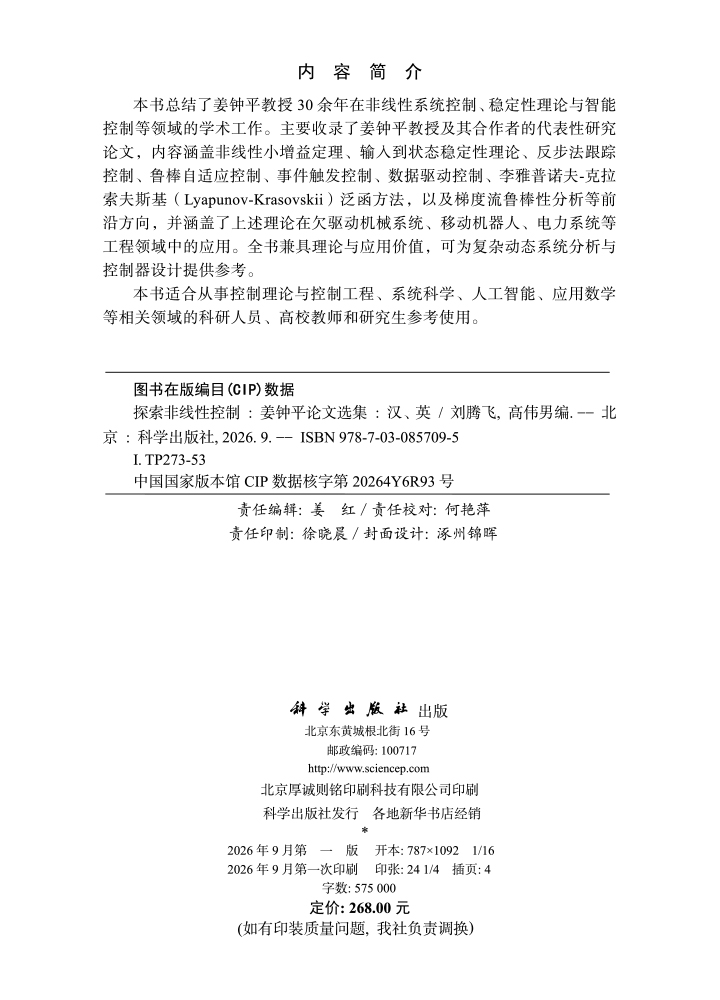
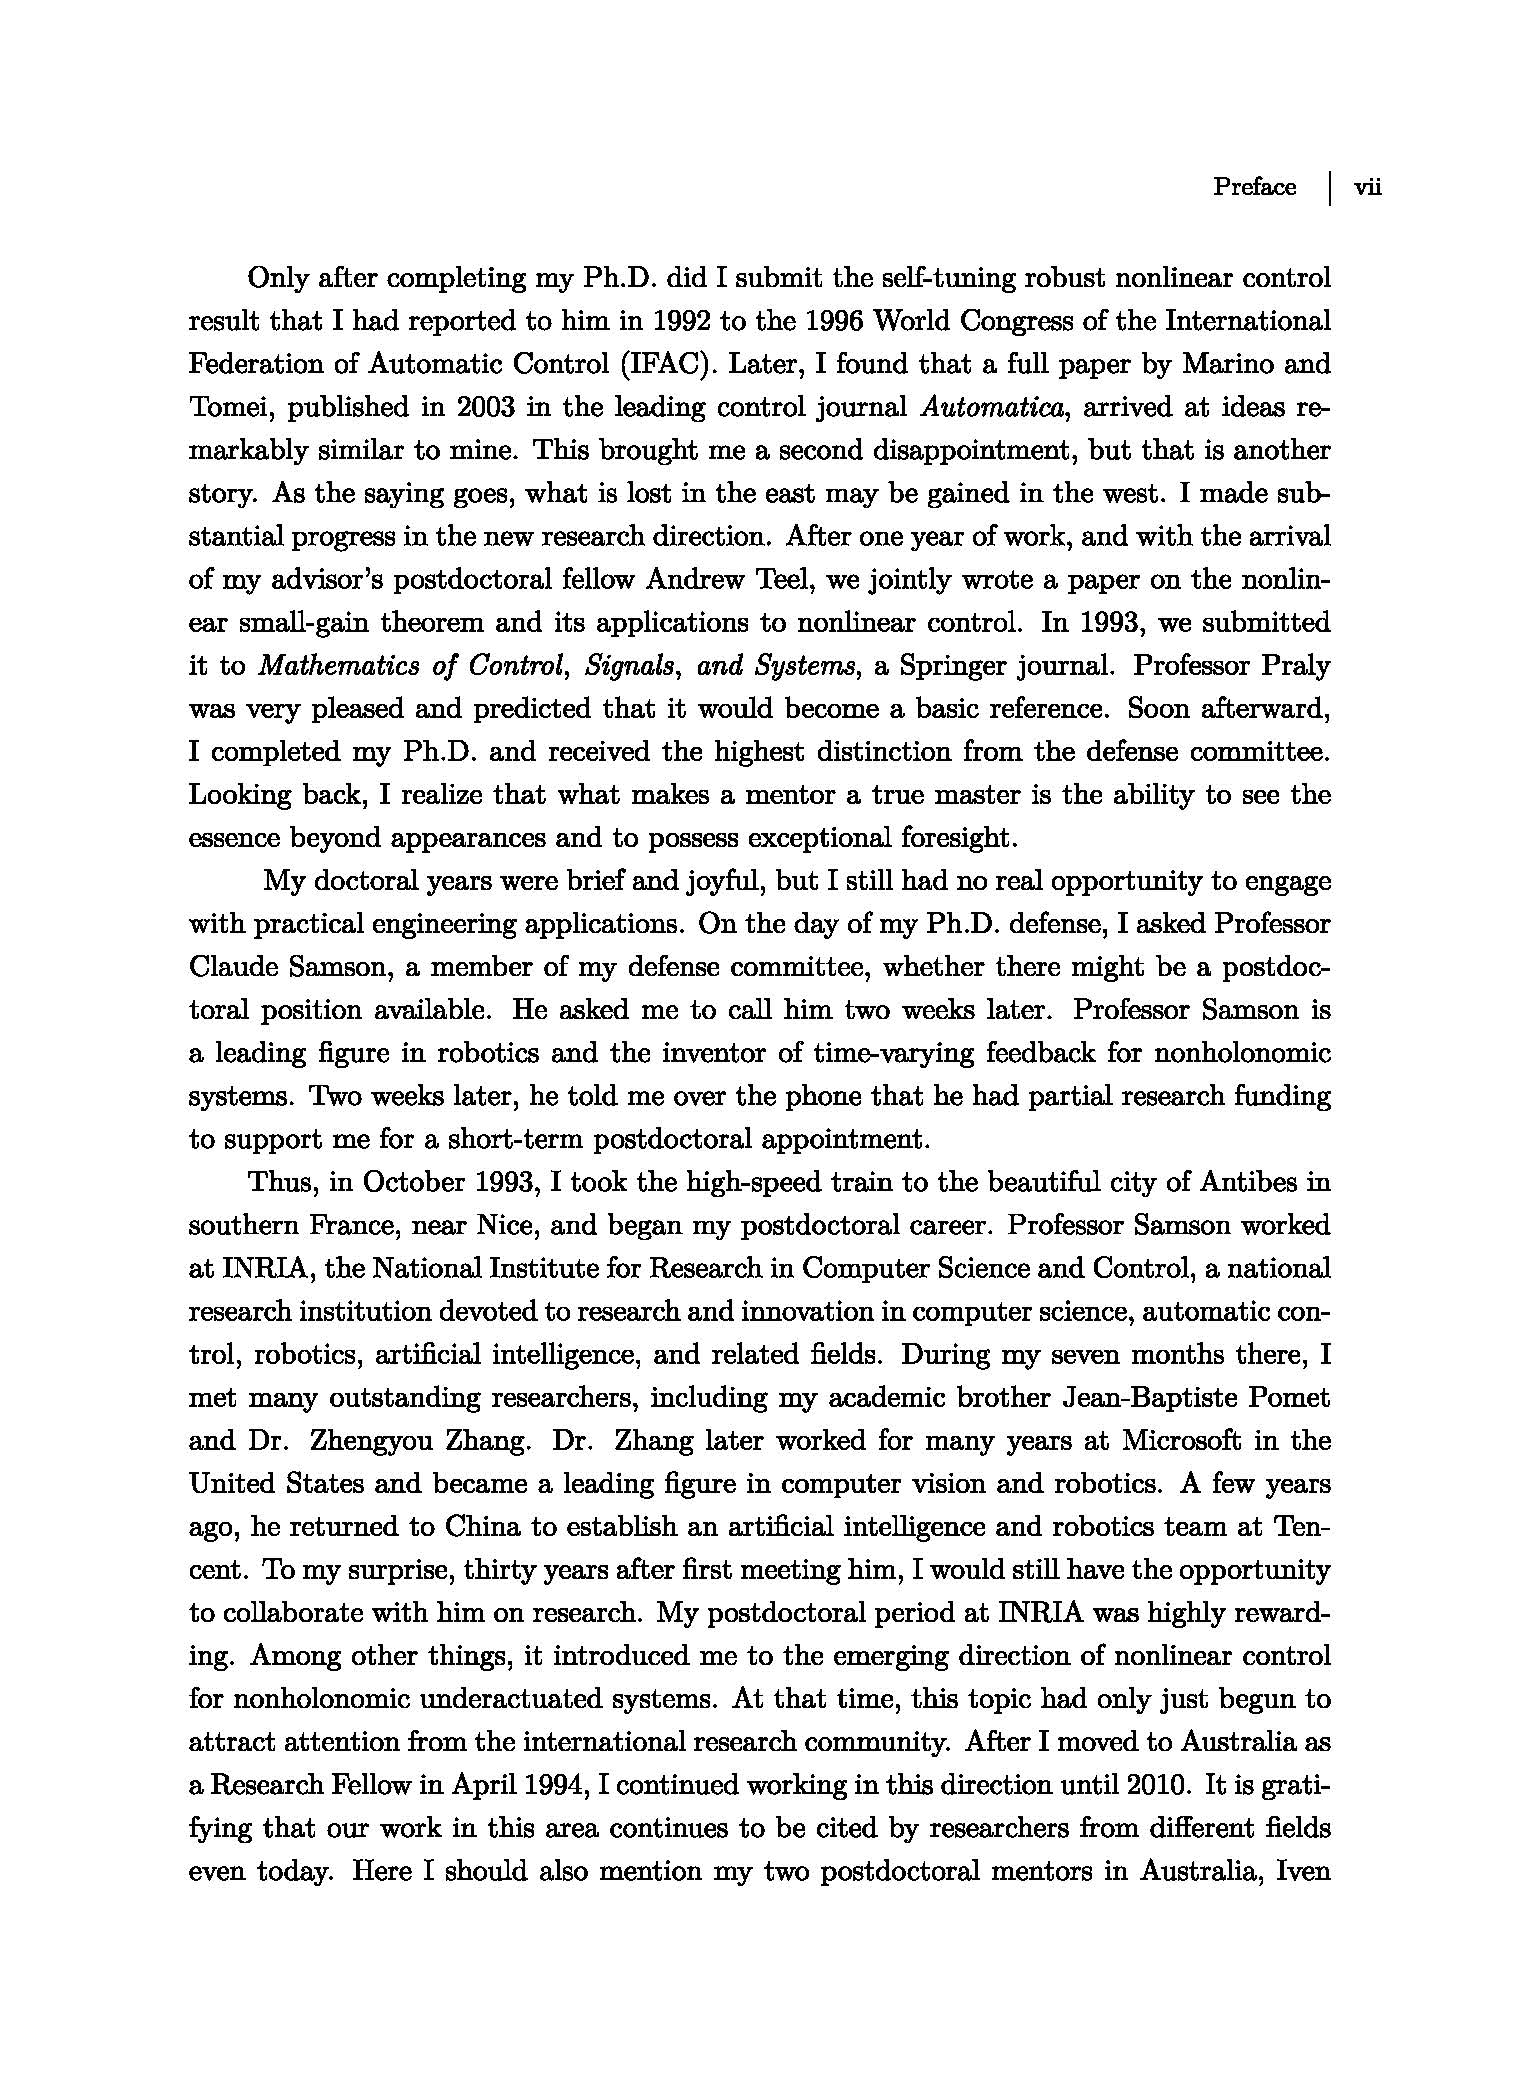
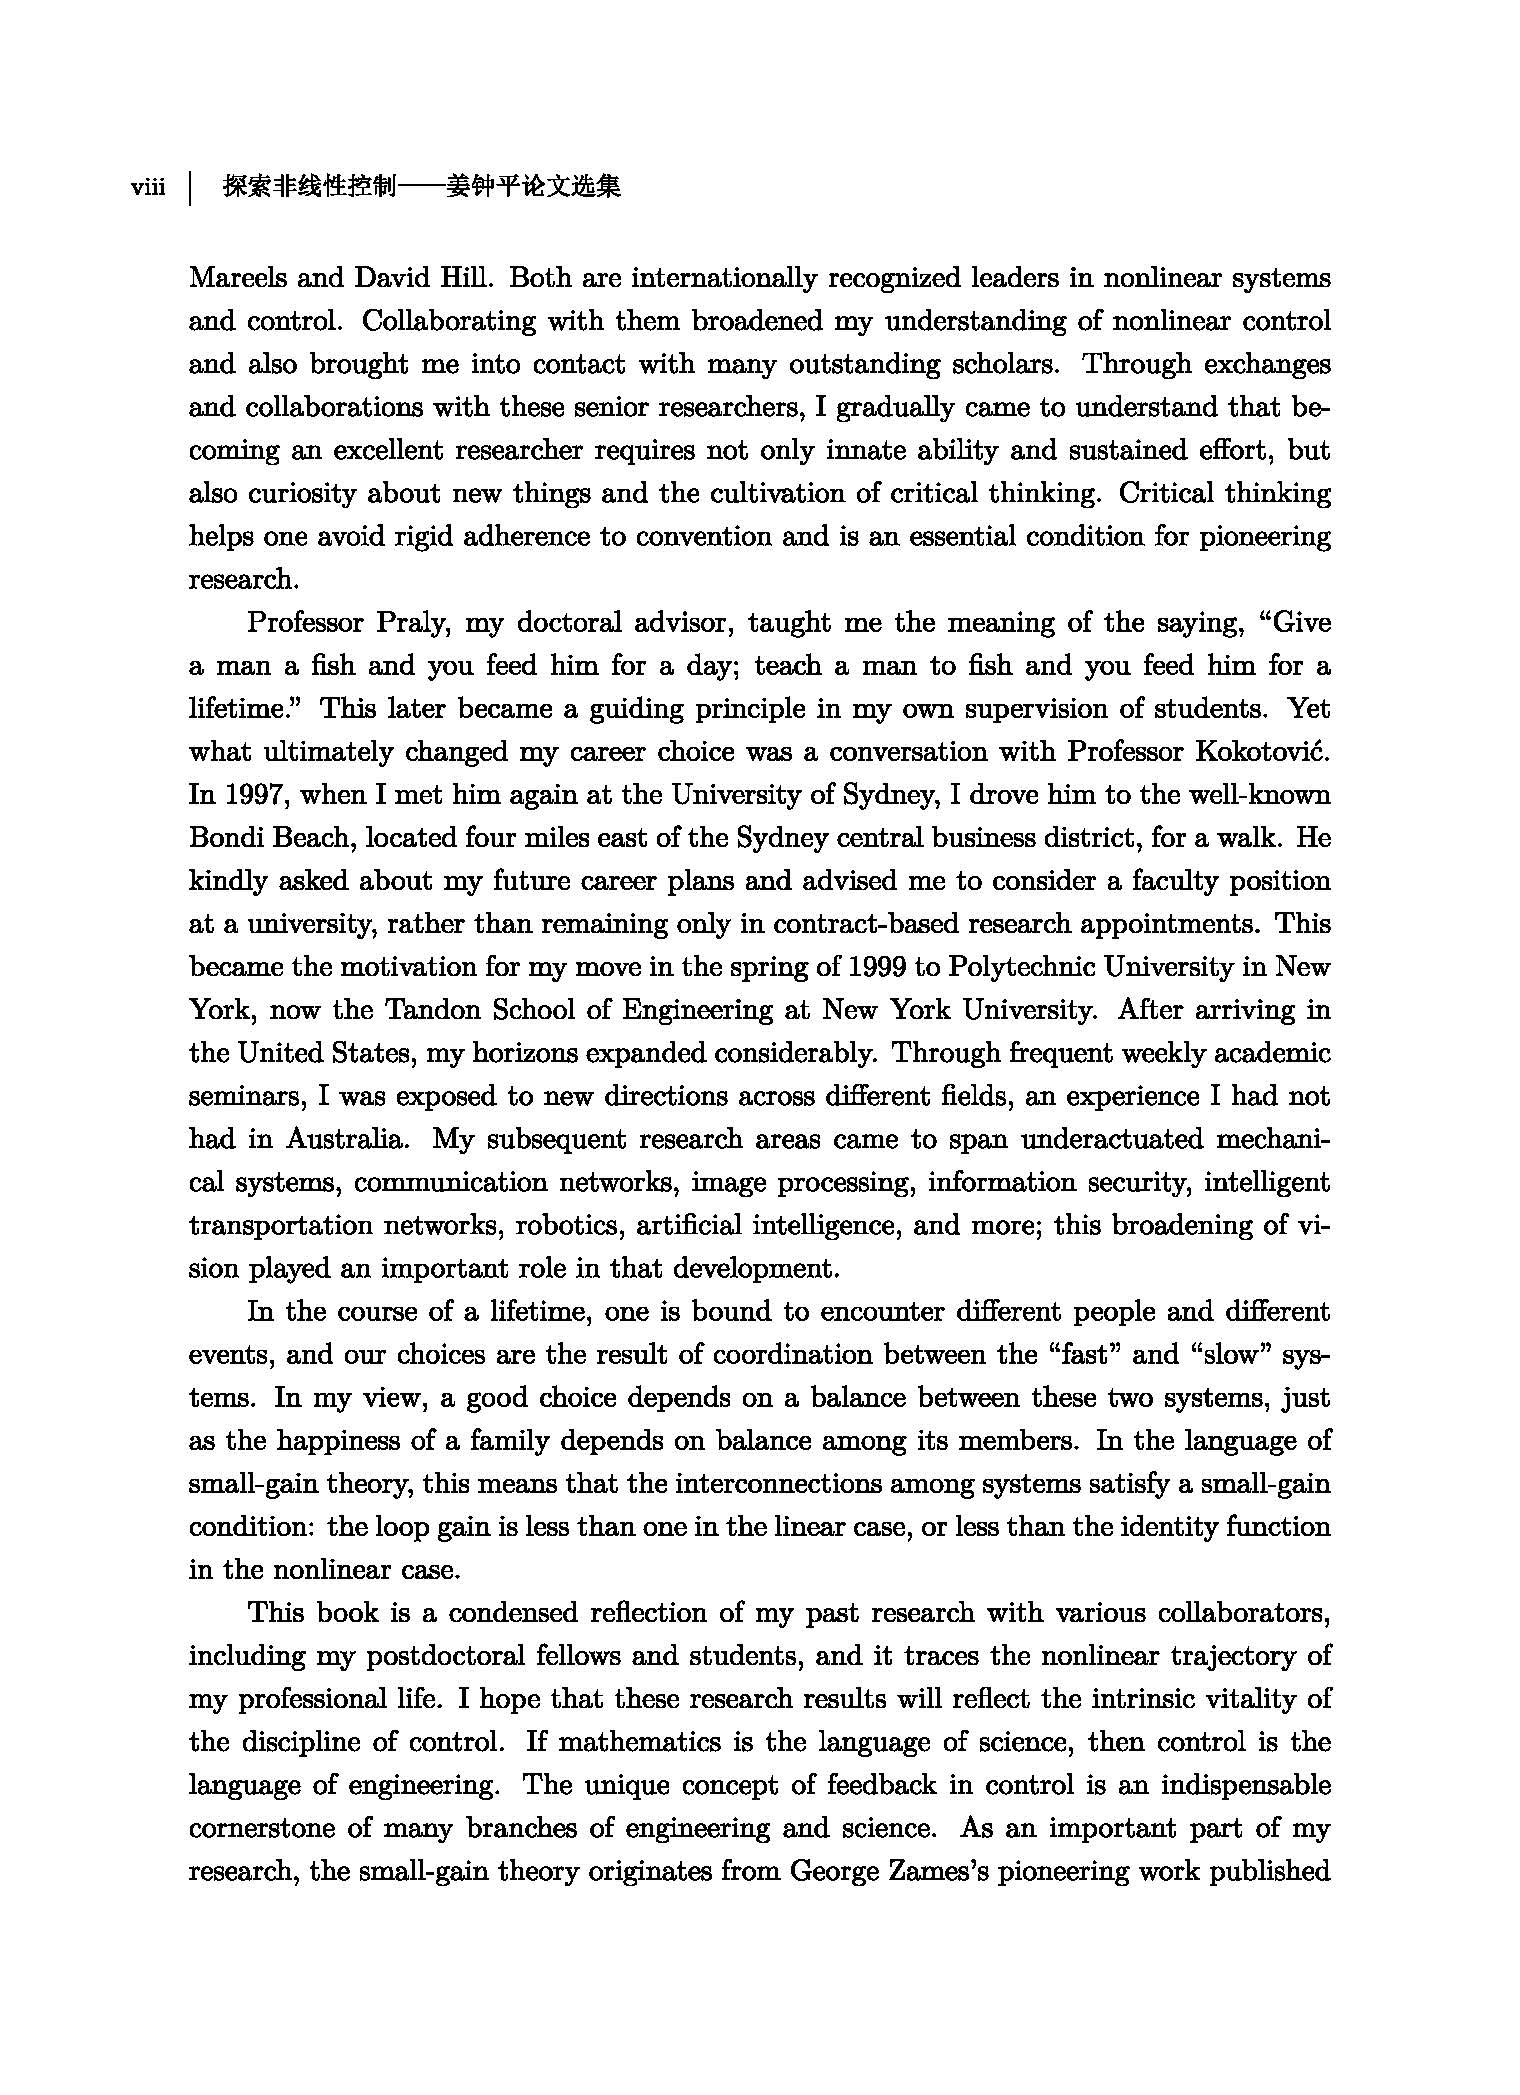
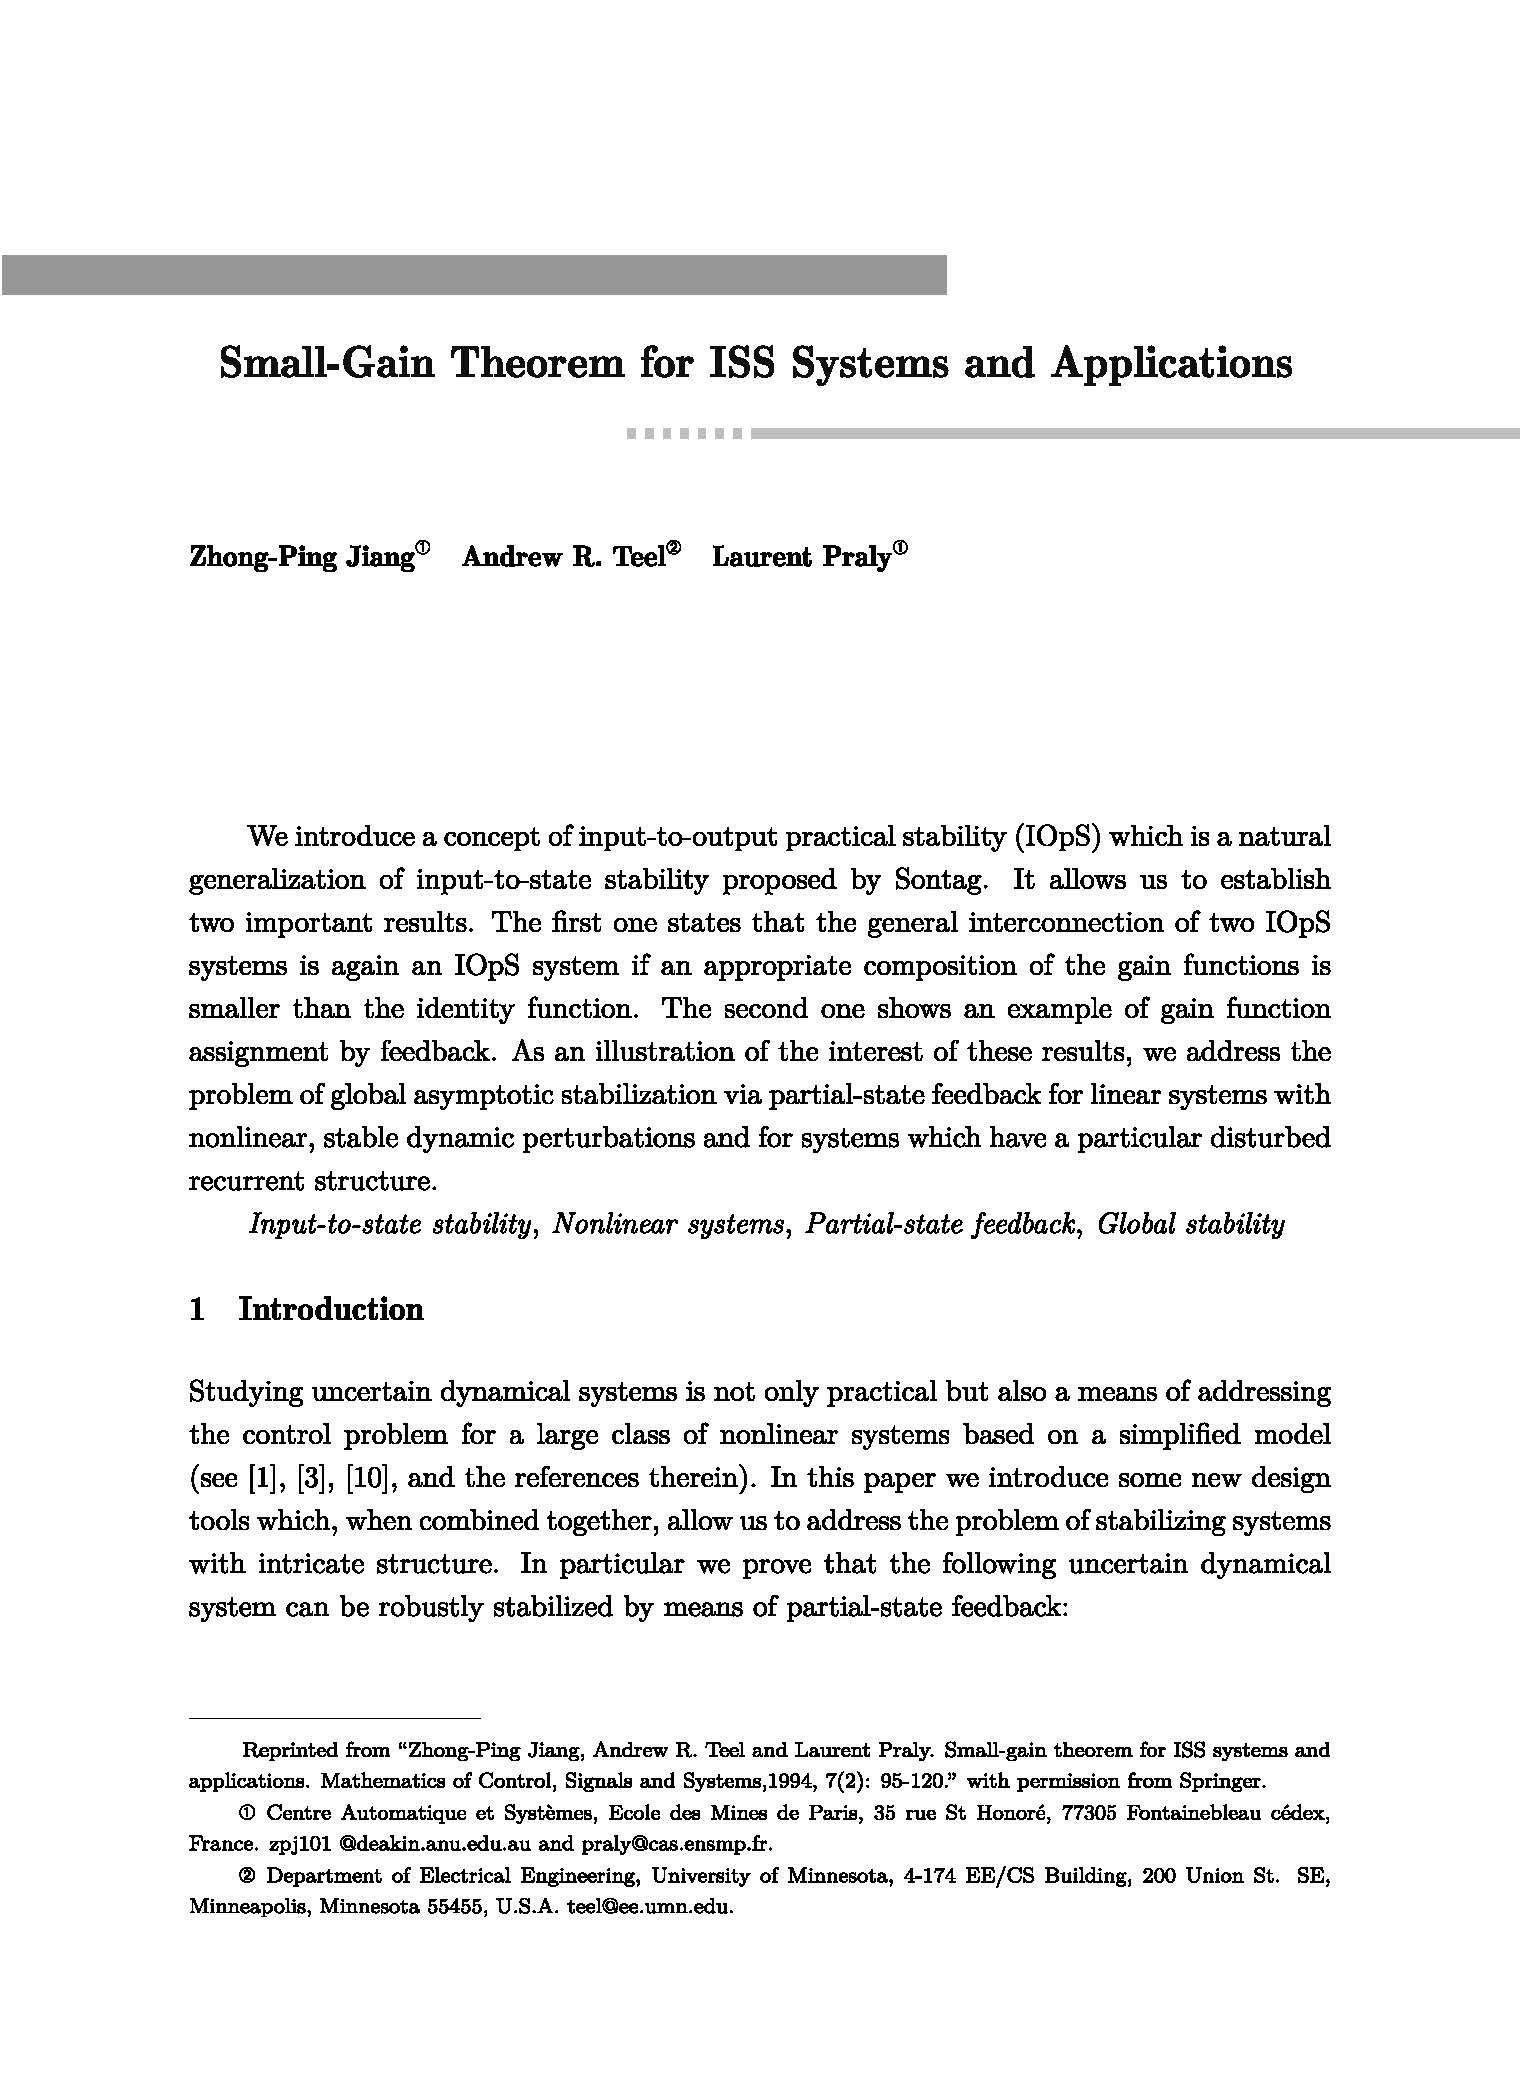
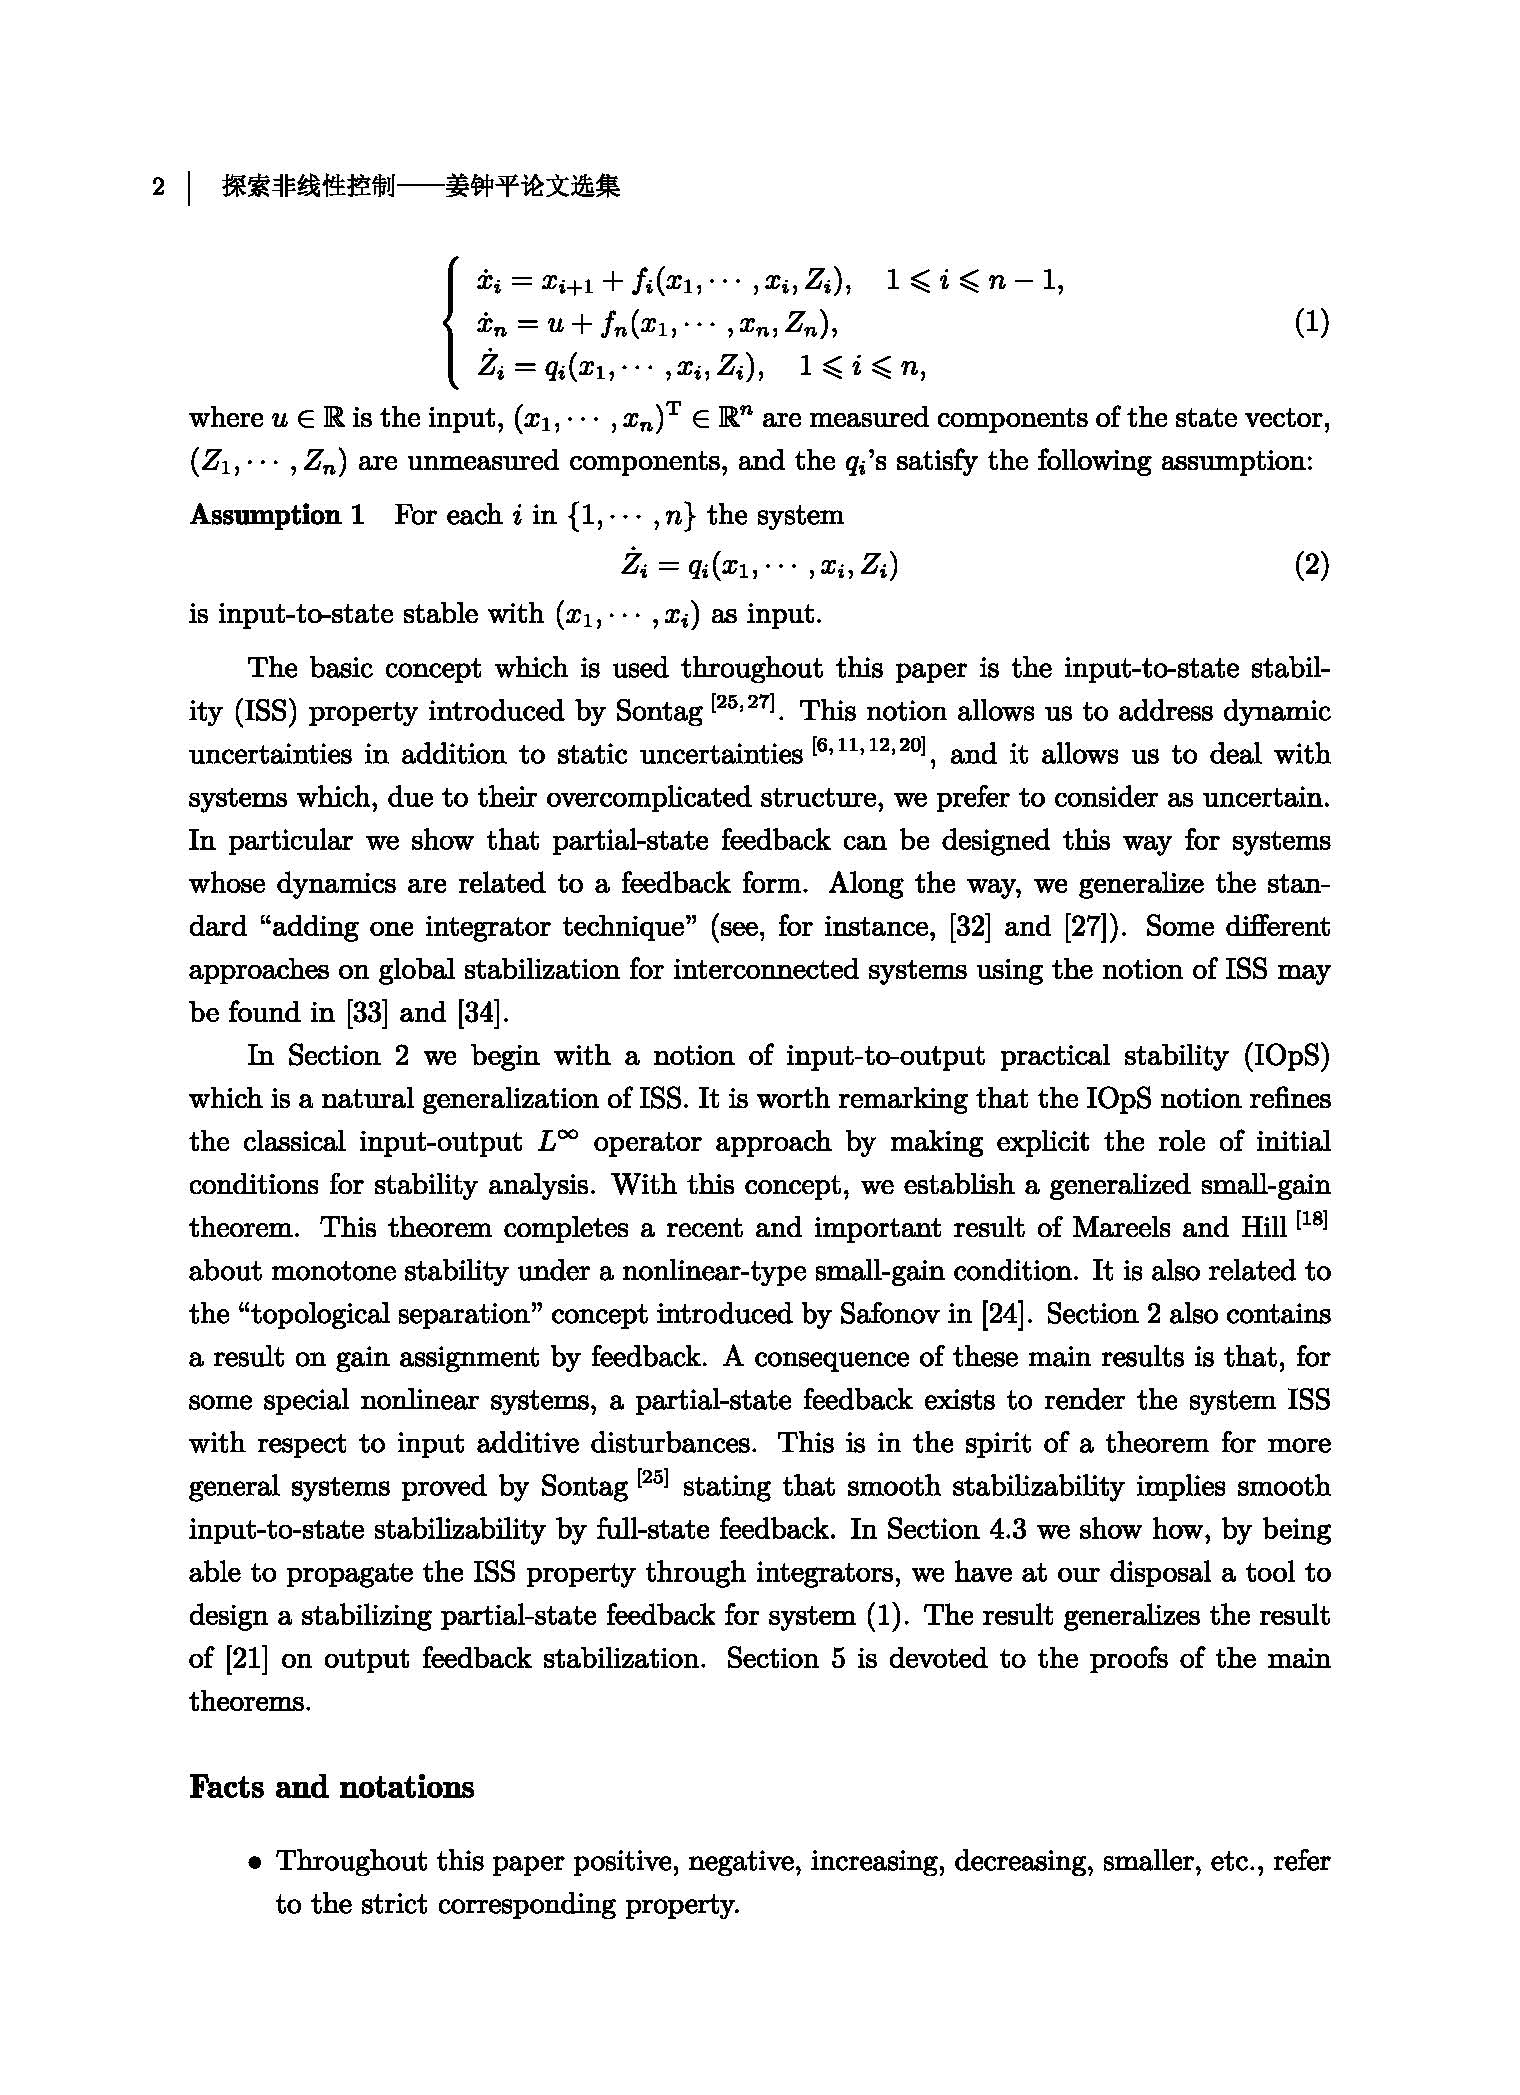
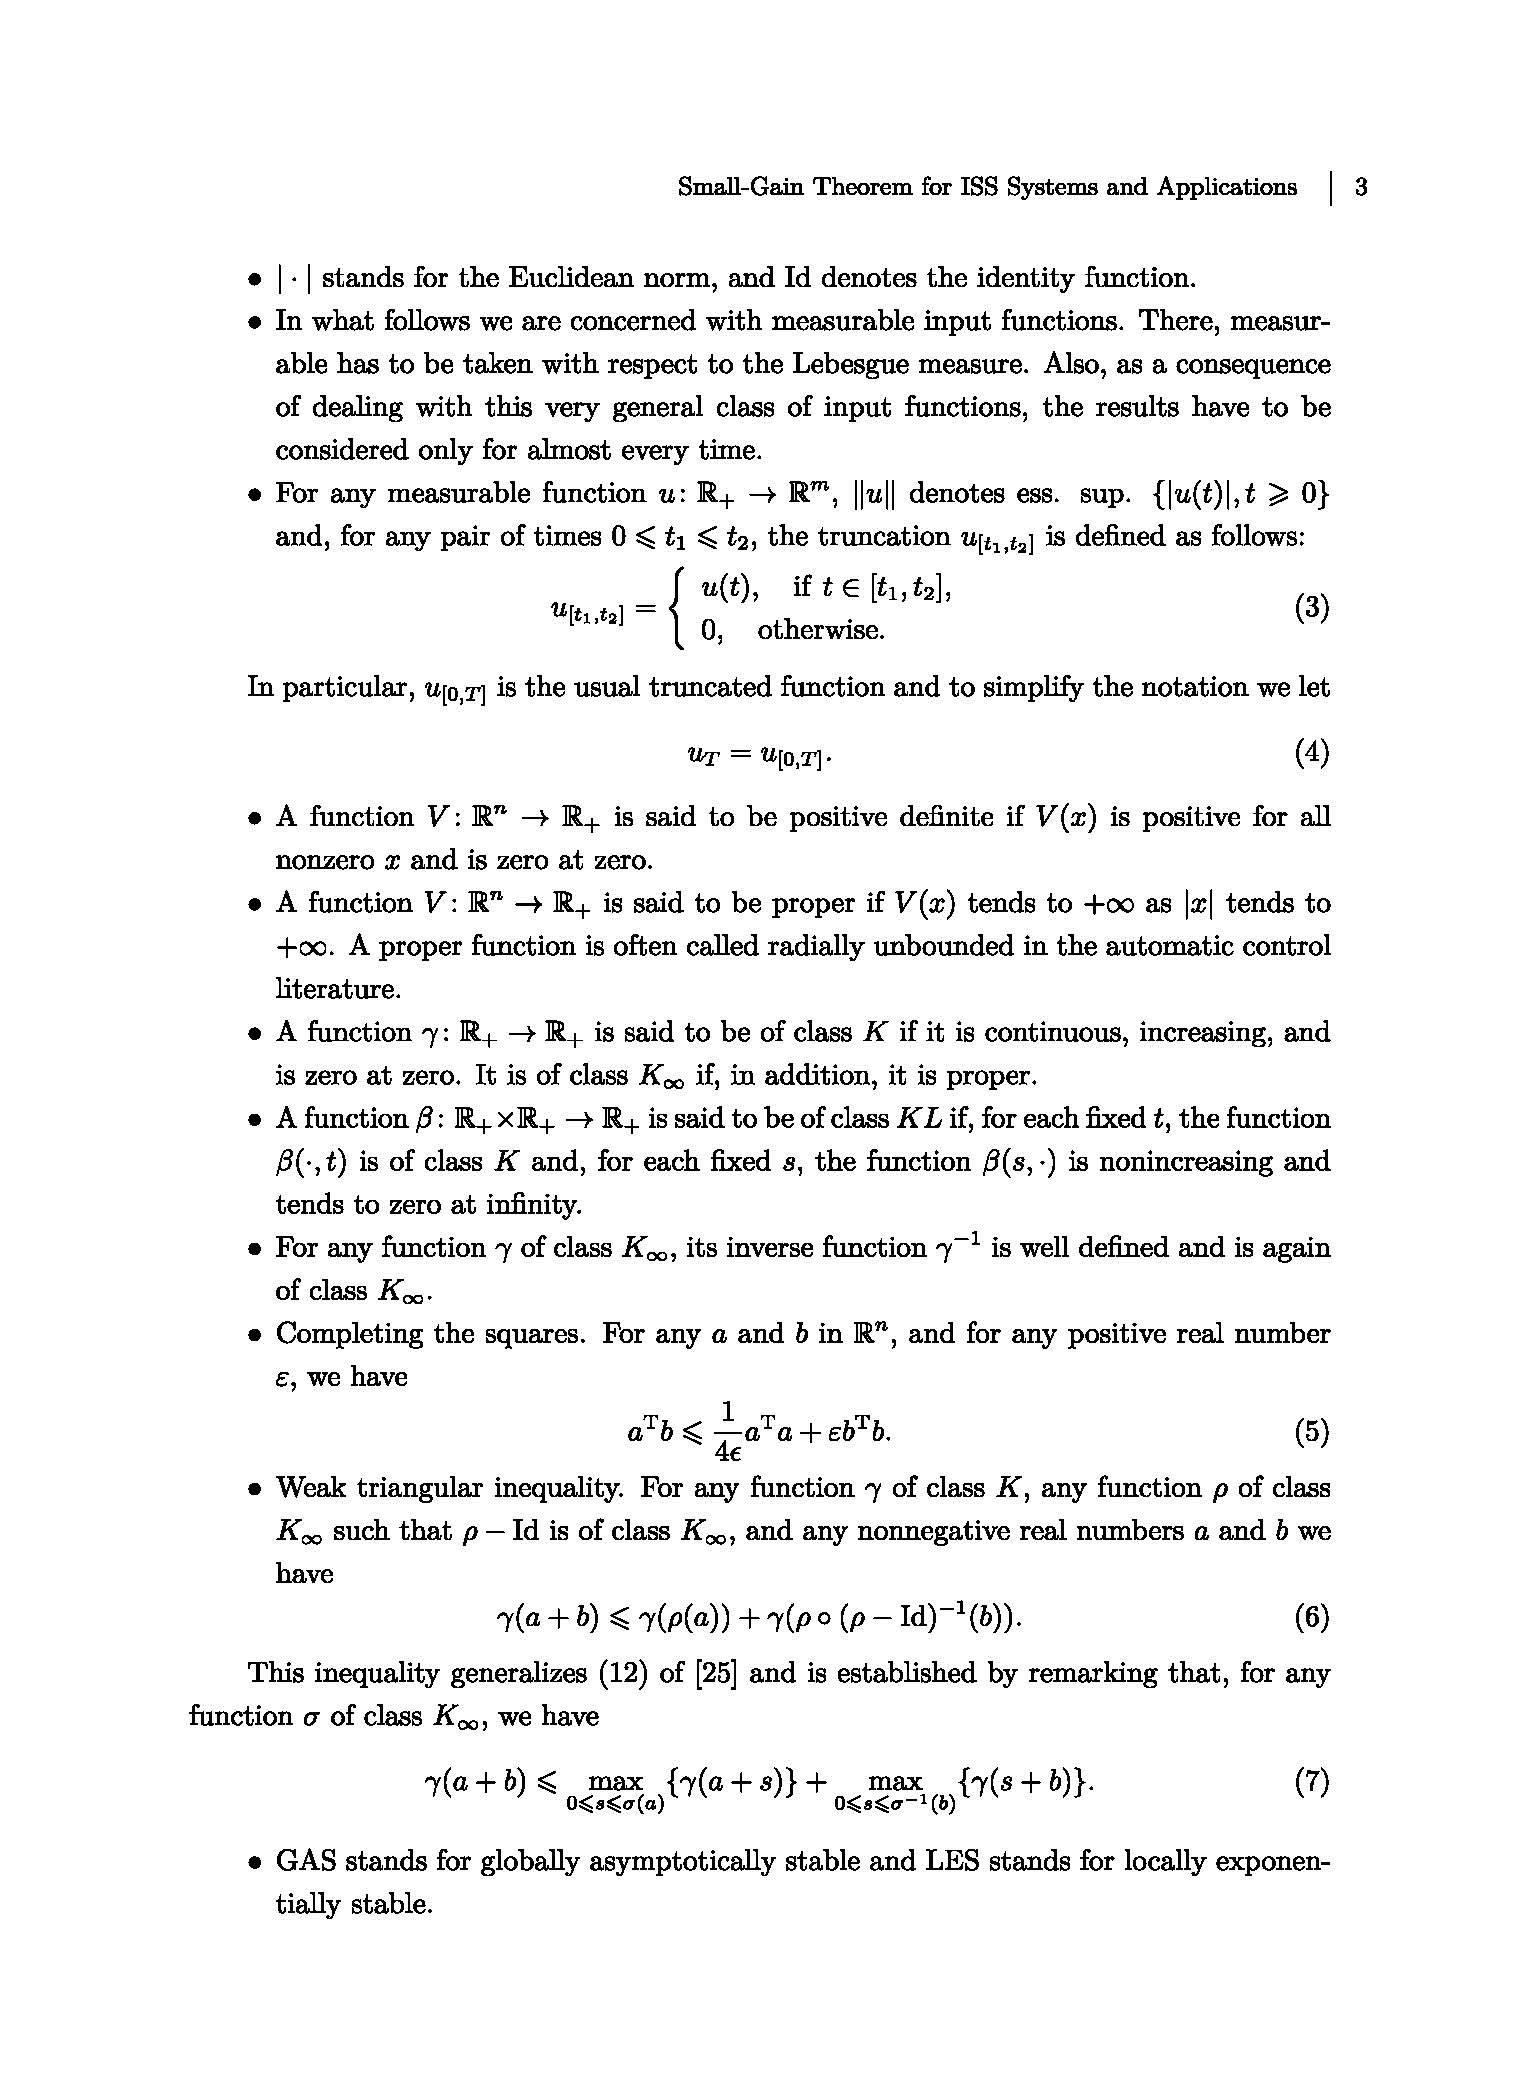
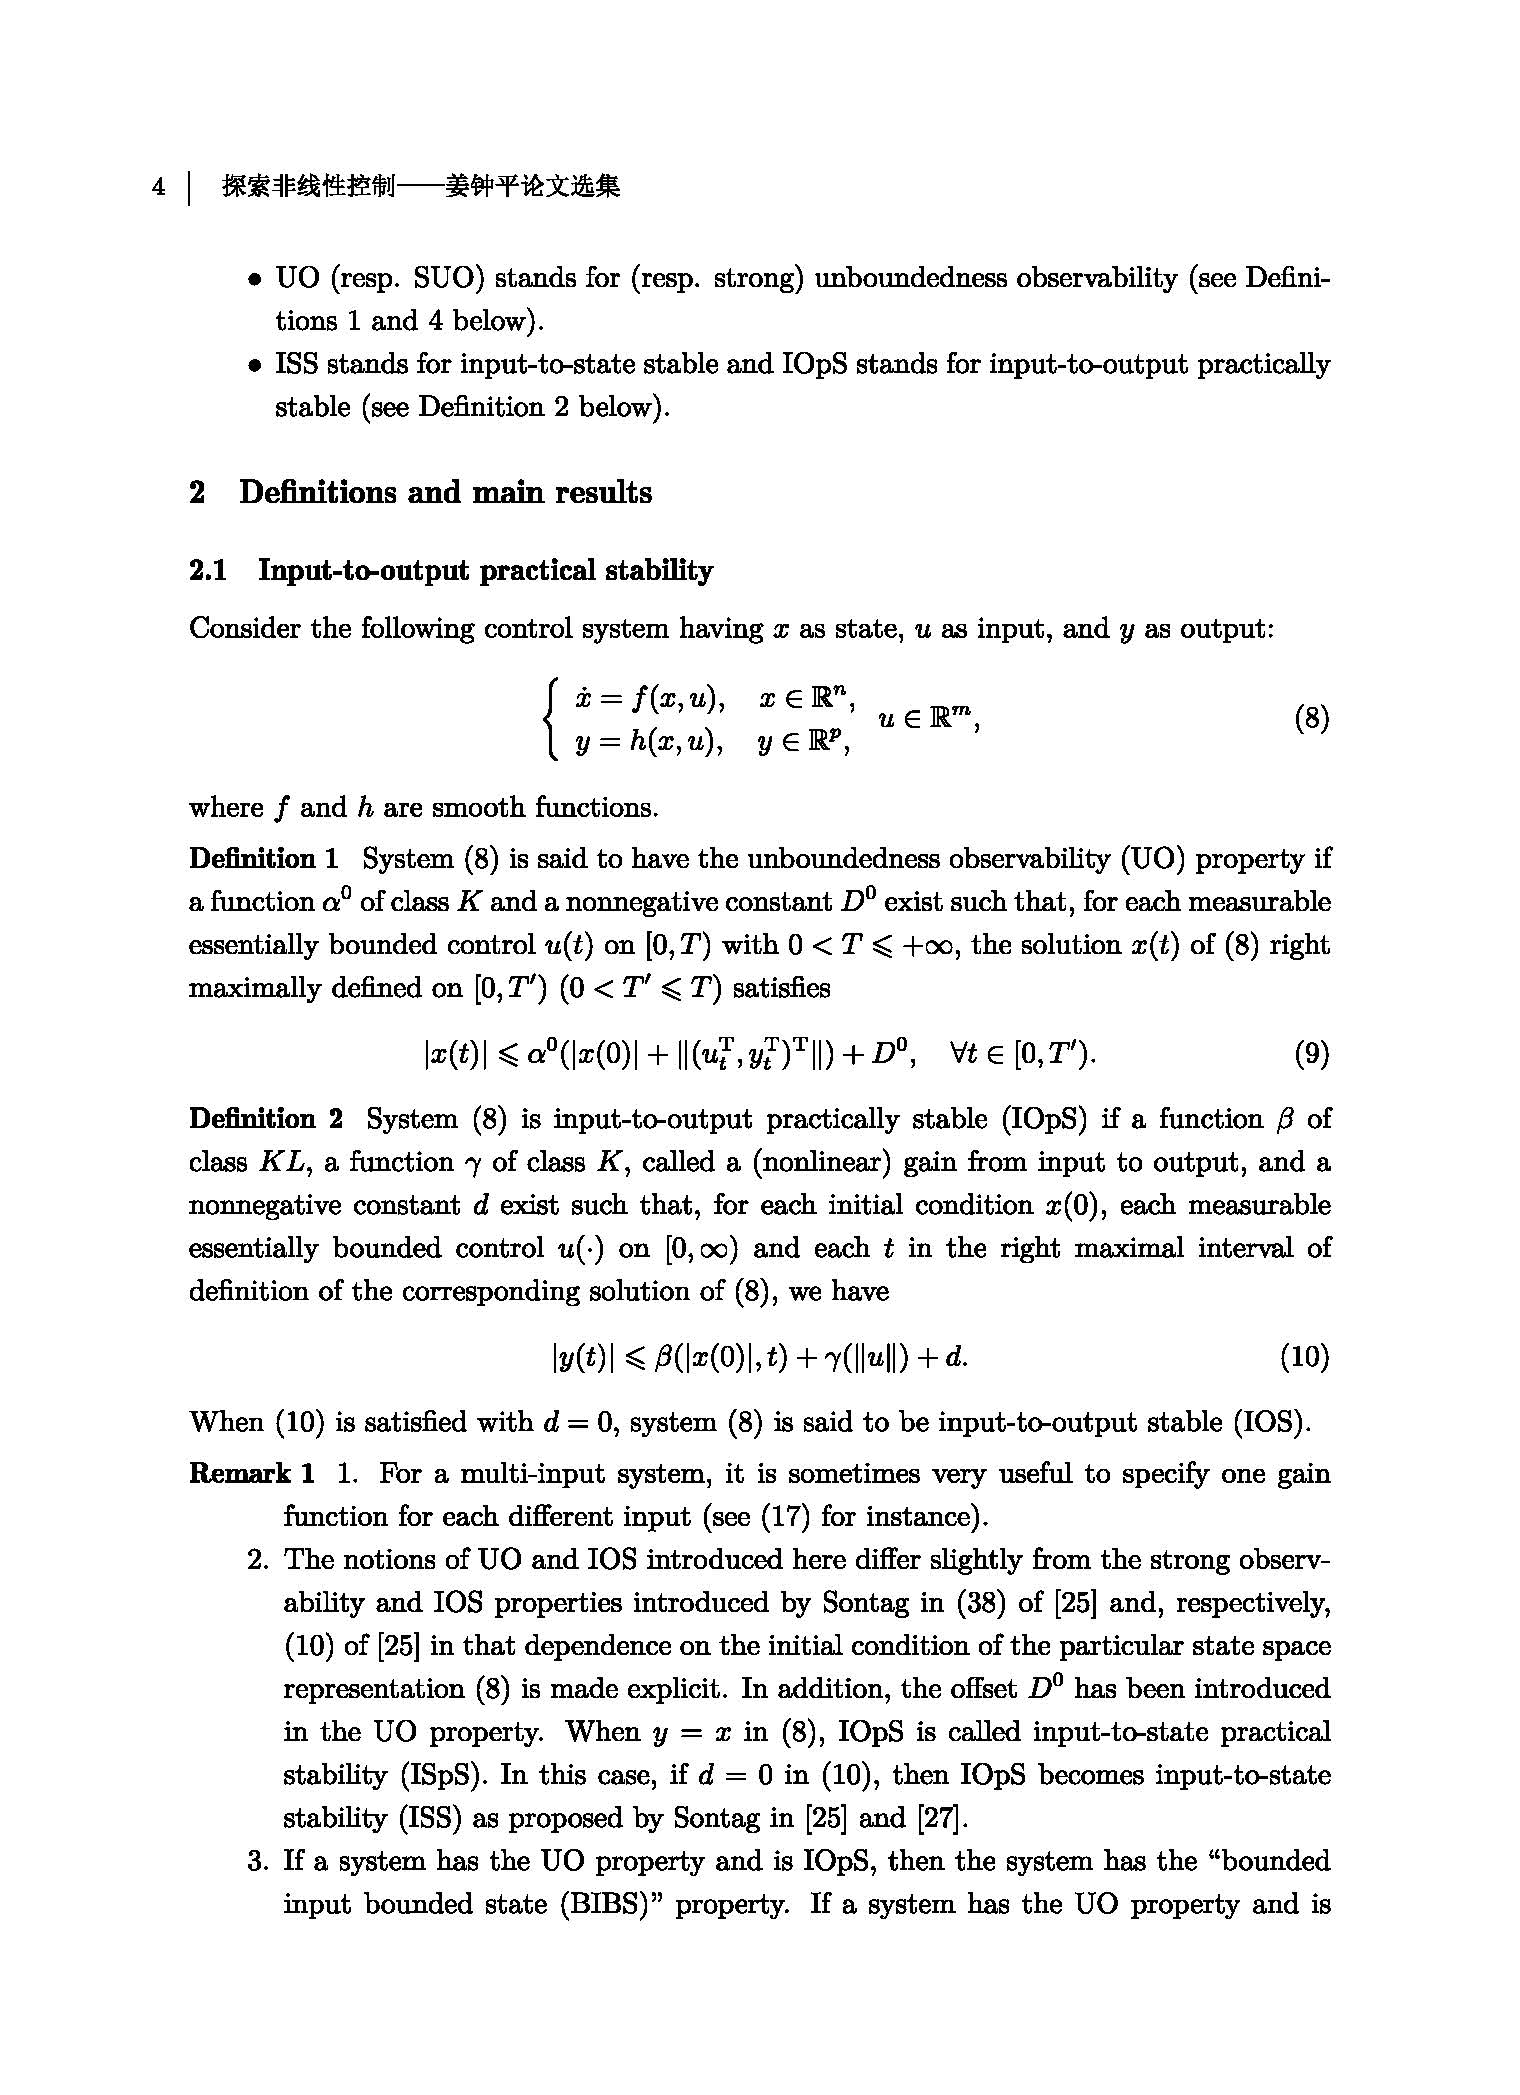
本书总结了姜钟平教授30余年在非线性系统控制、稳定性理论与智能控制等领域的学术工作。主要收录了姜钟平教授及其合作者的代表性研究论文,内容涵盖非线性小增益定理、输入到状态稳定性理论、反步法跟踪控制、鲁棒自适应控制、事件触发控制、数据驱动控制、李雅普诺夫-克拉索夫斯基(Lyapunov-Krasovskii)泛函方法,以及梯度流鲁棒性分析等前沿方向,并涵盖了上述理论在欠驱动机械系统、移动机器人、电力系统等工程领域中的应用。全书兼具理论与应用价值,可为复杂动态系统分析与控制器设计提供参考。
目录:
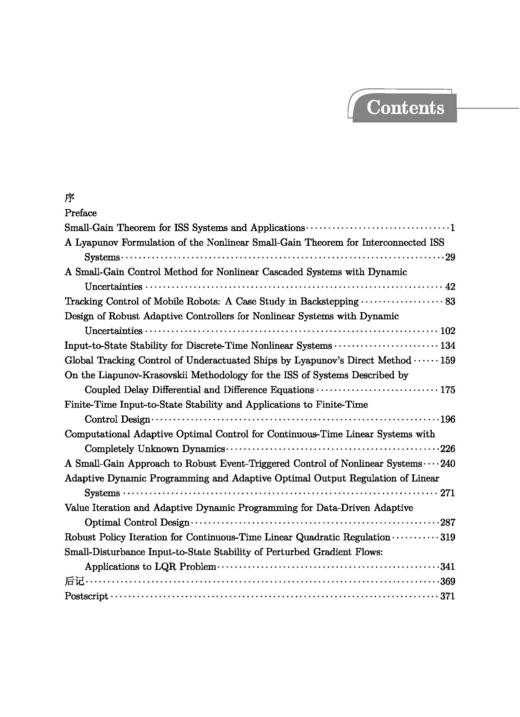
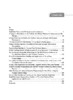
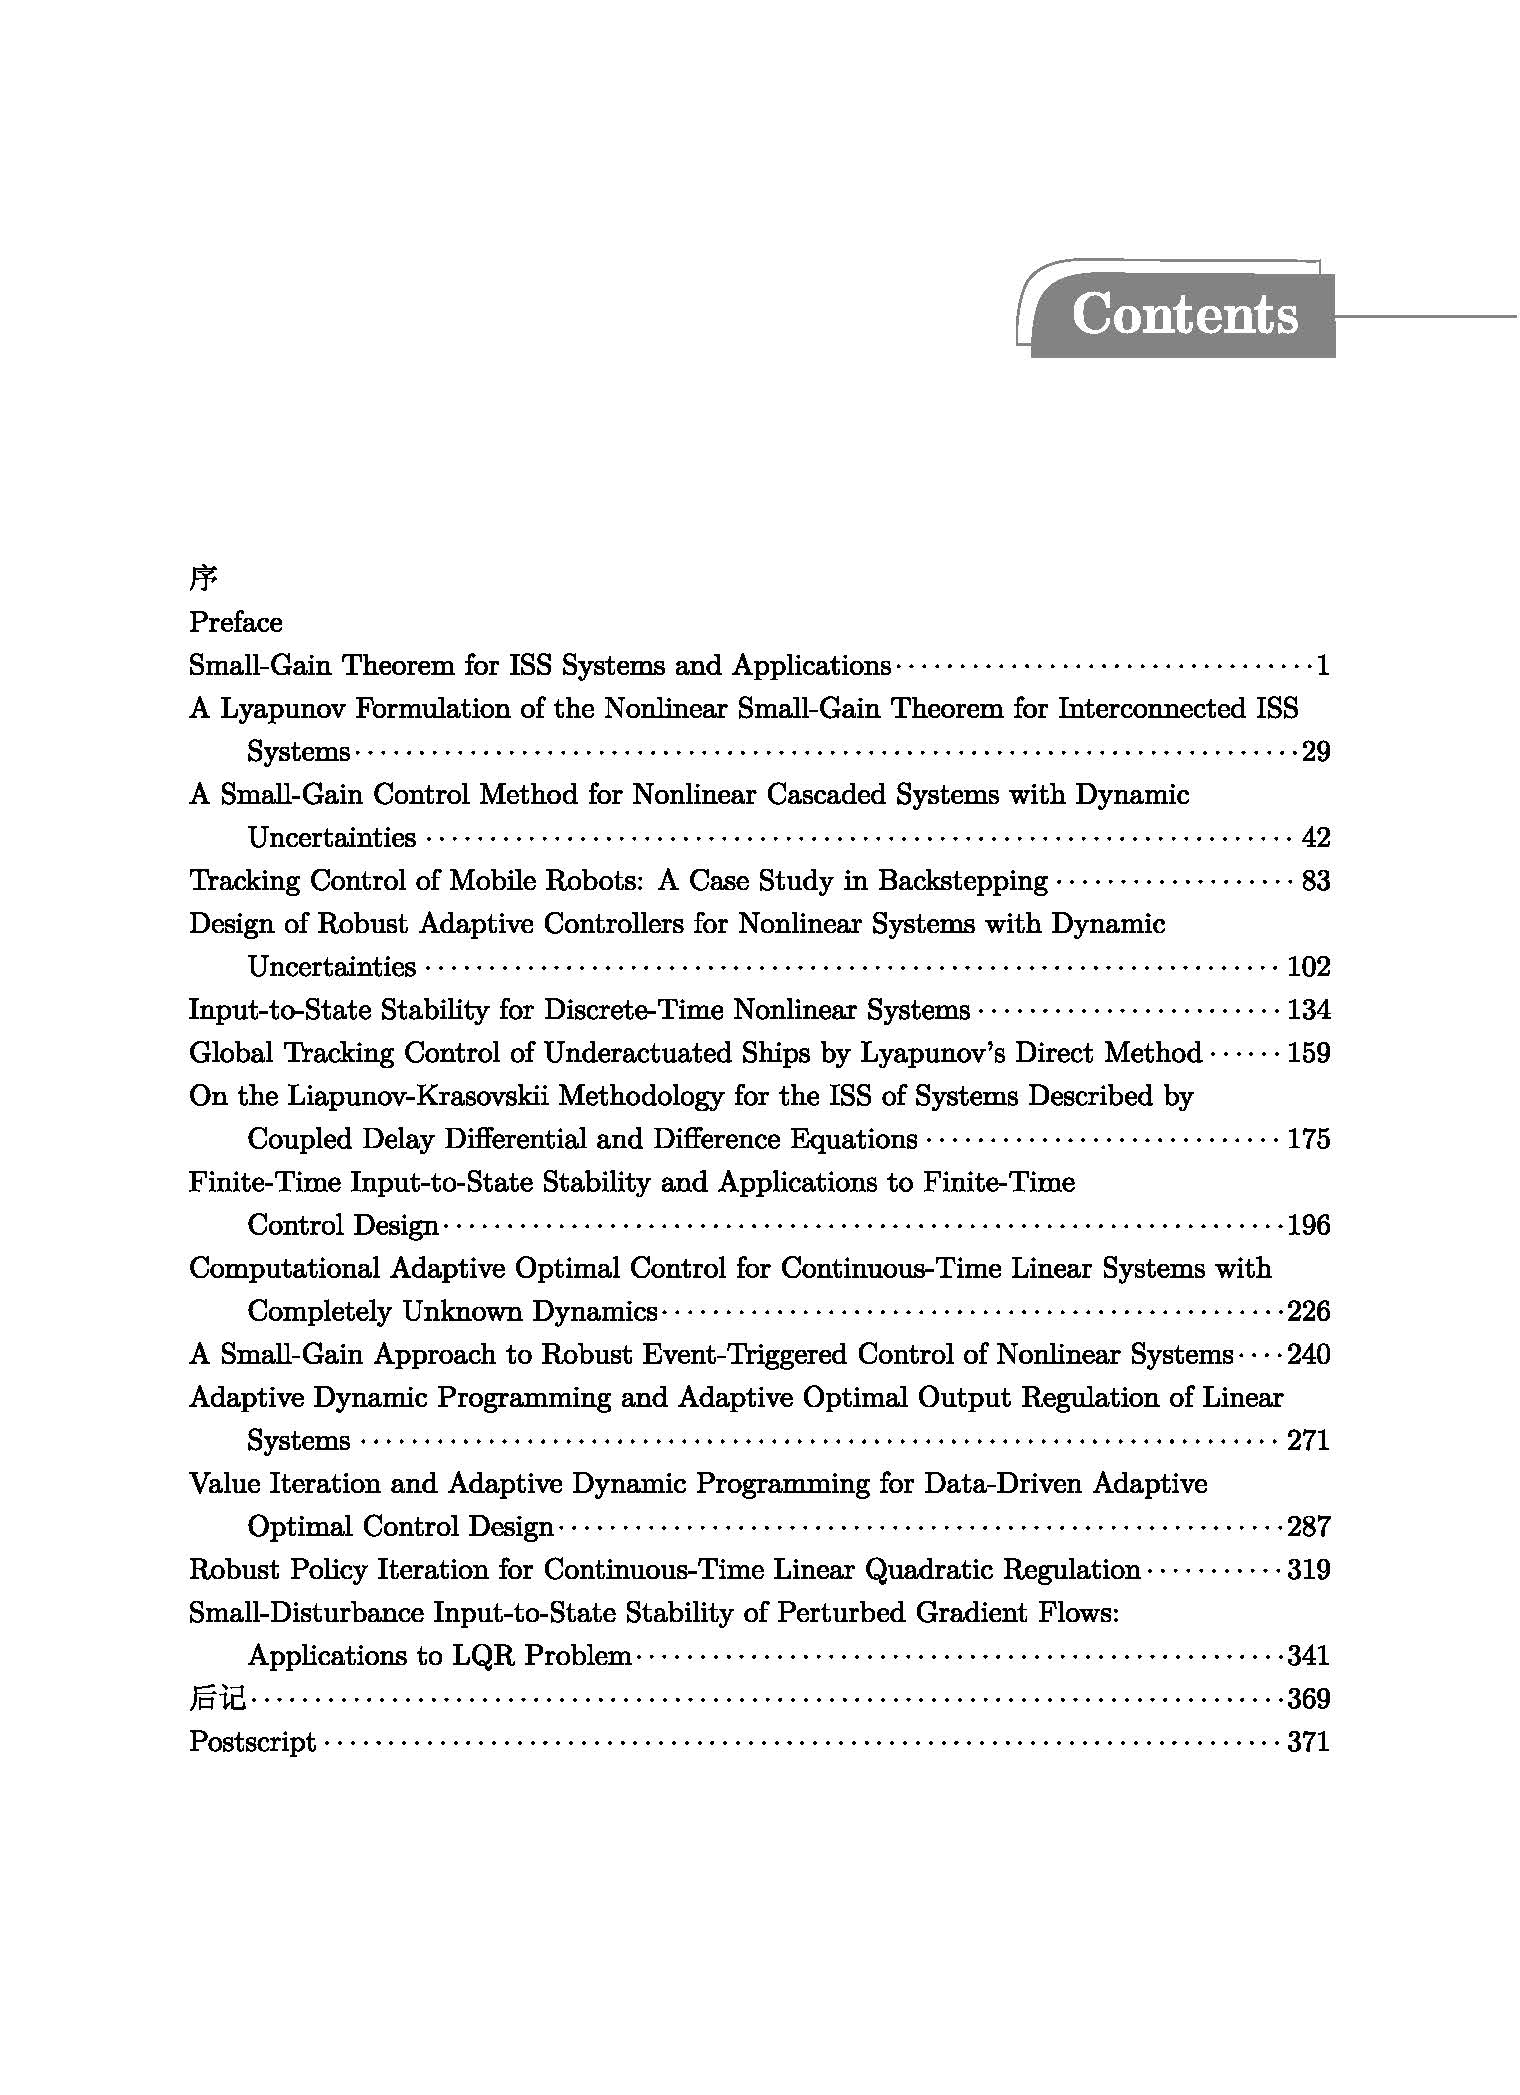
Contents
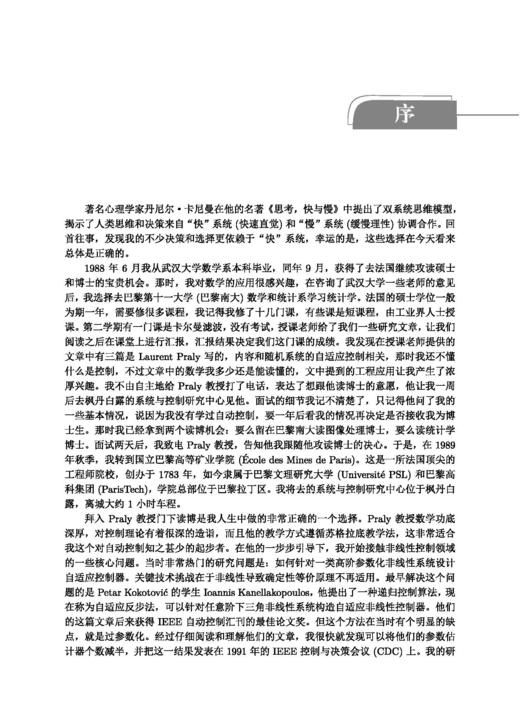
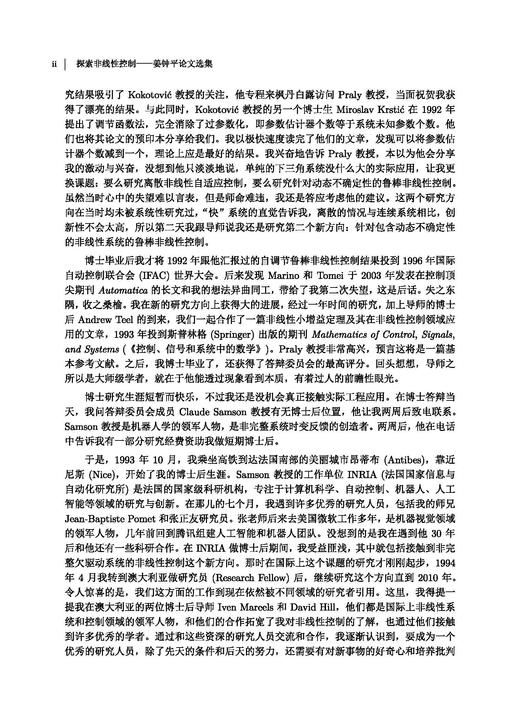
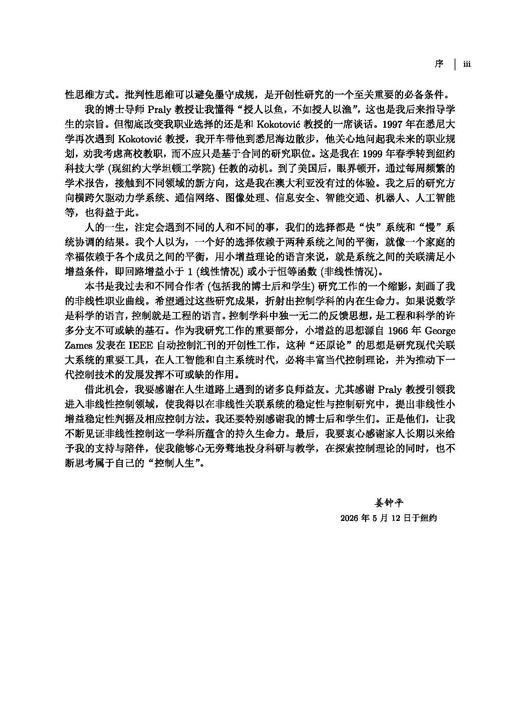
序
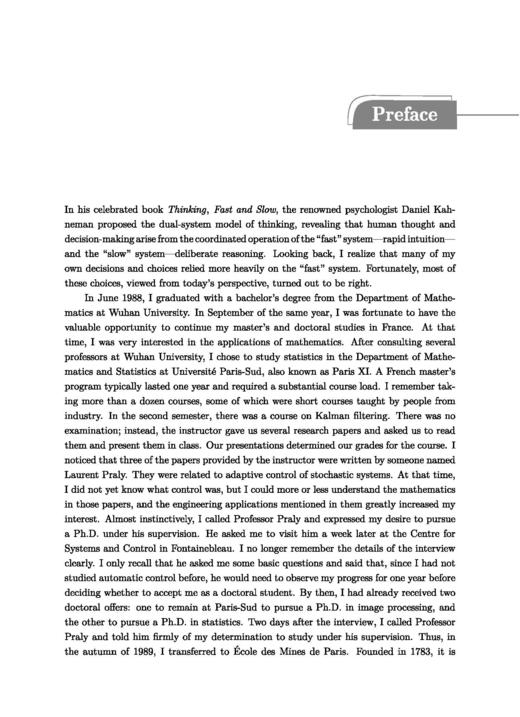
Preface
Small?Gain Theorem for ISS Systems and Applications 1
A Lyapunov Formulation of the Nonlinear Small?Gain Theorem for Interconnected ISS Systems 29
A Small?Gain Control Method for Nonlinear Cascaded Systems with Dynamic Uncertainties 42
Tracking Control of Mobile Robots: A Case Study in Backstepping 83
Design of Robust Adaptive Controllers for Nonlinear Systems with Dynamic Uncertainties 102
Input?to?State Stability for Discrete?Time Nonlinear Systems 134
Global Tracking Control of Underactuated Ships by Lyapunov’s Direct Method 159
On the Liapunov?Krasovskii Methodology for the ISS of Systems Described by Coupled Delay Differential and Difference Equations 175
Finite?Time Input?to?State Stability and Applications to Finite?Time Control Design 196
Computational Adaptive Optimal Control for Continuous?Time Linear Systems with Completely Unknown Dynamics 226
A Small?Gain Approach to Robust Event?Triggered Control of Nonlinear Systems 240
Adaptive Dynamic Programming and Adaptive Optimal Output Regulation of Linear Systems 271
Value Iteration and Adaptive Dynamic Programming for Data?Driven Adaptive Optimal Control Design 287
Robust Policy Iteration for Continuous?Time Linear Quadratic Regulation 319
Small?Disturbance Input?to?State Stability of Perturbed Gradient Flows: Applications to LQR Problem 341
后记 369
Postscript 371
- 科学出版社旗舰店 (微信公众号认证)
- 科学出版社秉承多年来形成的“高层次、高水平、高质量”和“严肃、严密、严格”的优良传统与作风,始终坚持为科技创新服务、为传播与普及科学知识服务、为科学家和广大读者服务的宗旨。
- 扫描二维码,访问我们的微信店铺
- 随时随地的购物、客服咨询、查询订单和物流...